NOV 9, 2026
THE VERSOR TEAM
8 MIN READ
THE VERSOR TEAM
8 MIN READ
Real-world data as the foundation for robotics simulations
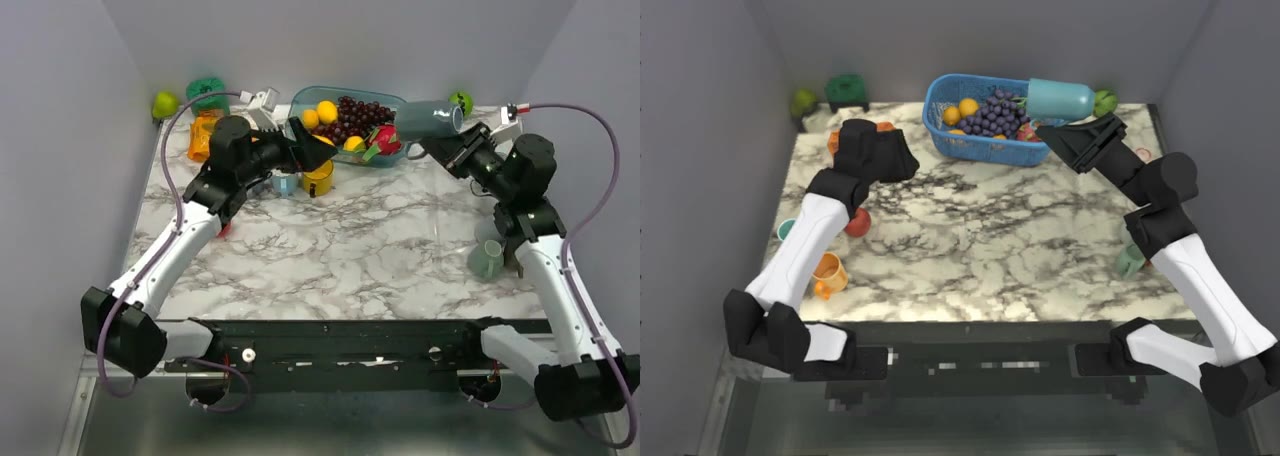
- We release 1,000 simulation environments for five bimanual tasks from the ABC dataset, created real-to-sim from real robot trajectories.
- Our environments show strong sim-to-real performance correlation on ABC's learned policies and reproduce real-world failures in sim.
- Policies trained in our simulation show strong sim-to-real performance on a new robot cell, achieving 4x higher success rates than policies trained on real data from other cells.
Simulation is only useful if its lessons transfer to the real world. At Versor, we are building real-to-sim-to-real systems that use real-world interactions to bridge the sim-to-real gap, turning real-world experience into realistic environments.
Read the post →